
Every year brings a completely new game challenge. We design, fabricate, and program two robots from the ground up to compete against universities worldwide.
Differential Swerve
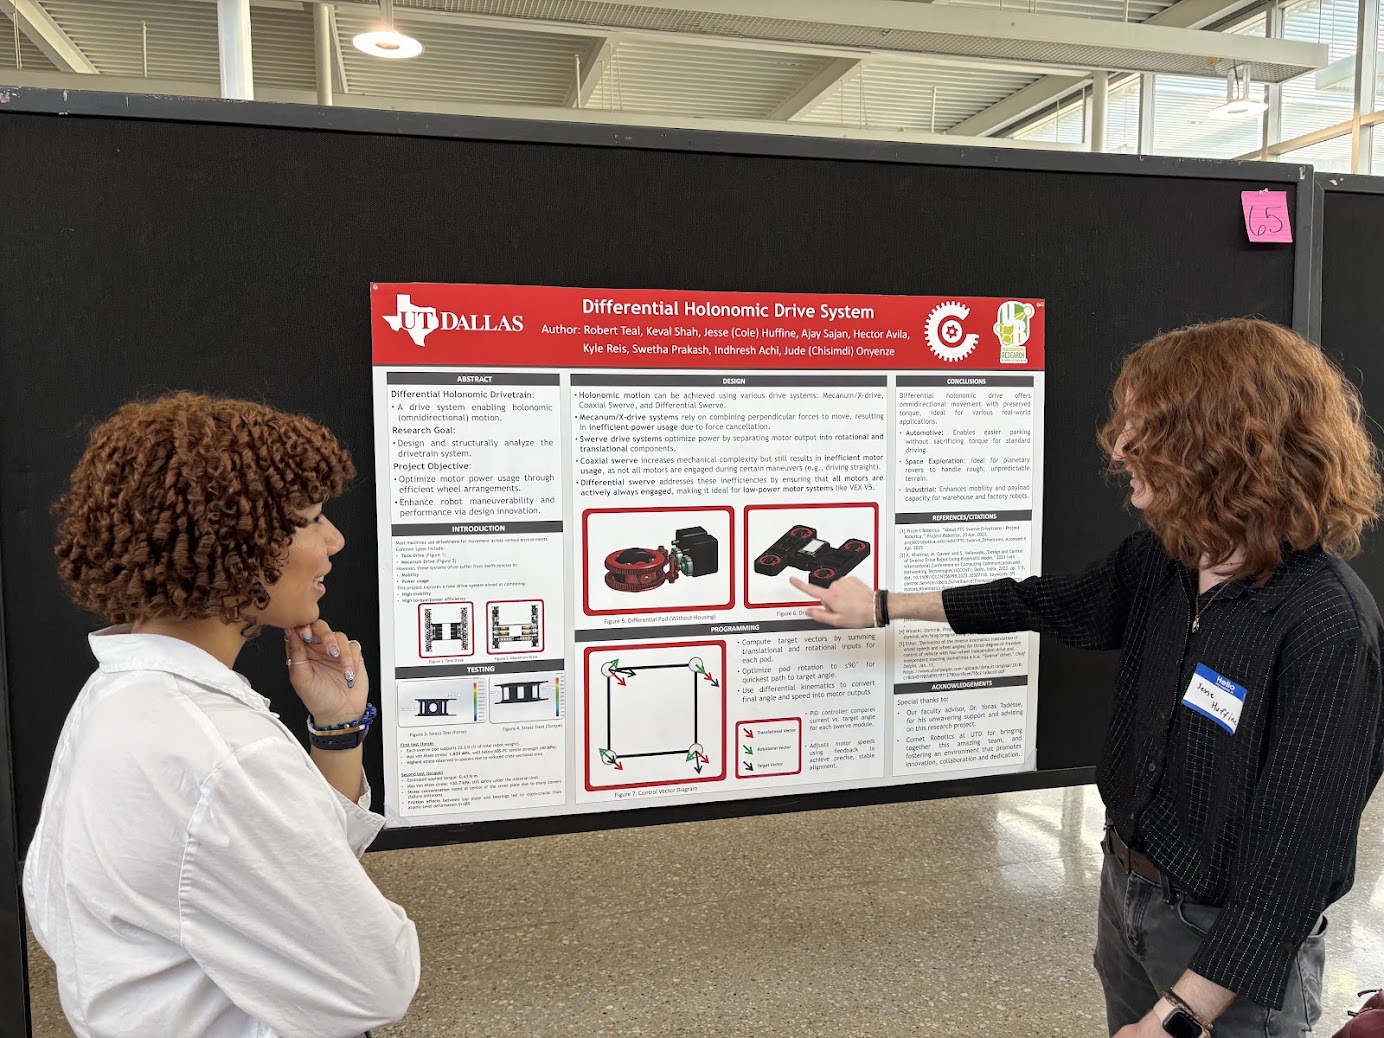
One of our biggest engineering accomplishments.
Unlike a standard holonomic drive, a differential swerve system steers and drives each module using two motors working differentially. This enables full omnidirectional movement without traditional strafing wheels, providing a massive advantage in pushing power on the field.
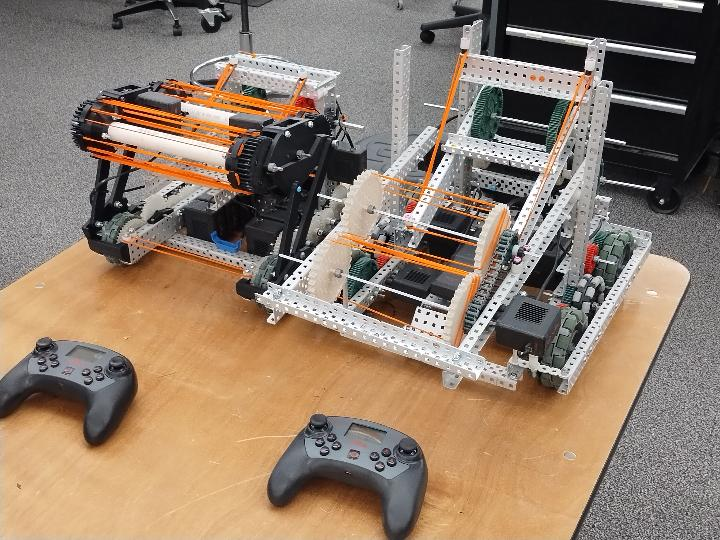
Over Under
Our first competition season in VEX U. This year, we went to the Texas VEX U Competition and ranked 5th in skills and tournament! On the worldwide skills leaderboard, we placed 82nd with a score of 80 (37 in auto, 43 in drivers).
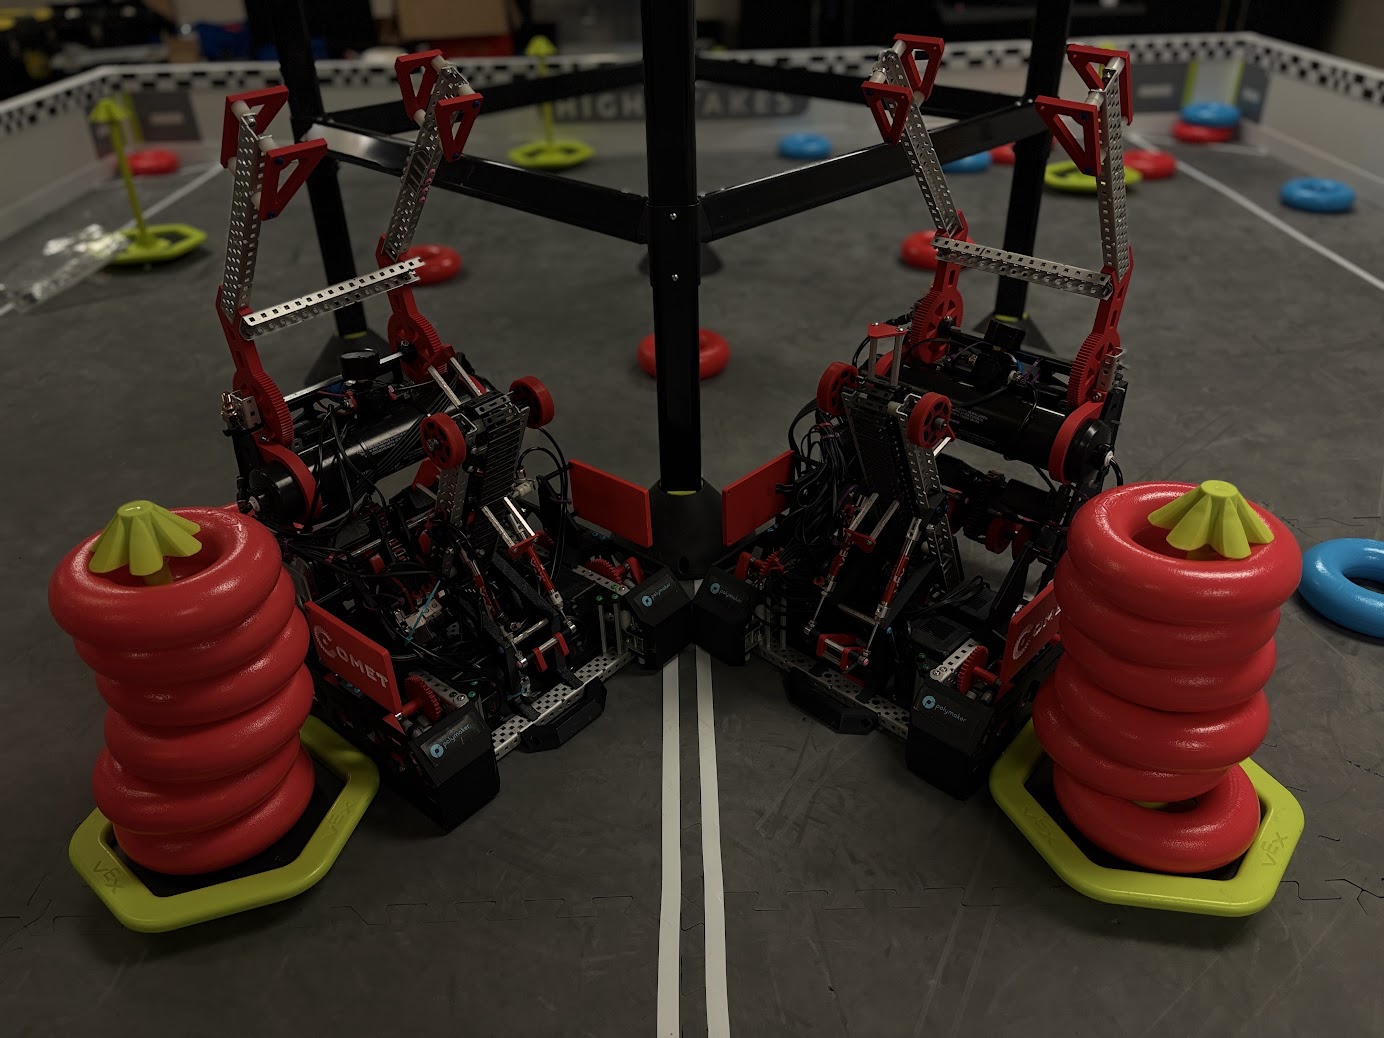
High Stakes
The second year we competed in the VEX U Robotics Competition. We went back to the Texas VEX U Competition where we ranked 5th in skills and 9th in tournament! On the world skills leaderboard, we placed 59th with a score of 73 (27 in auto, 46 in drivers).
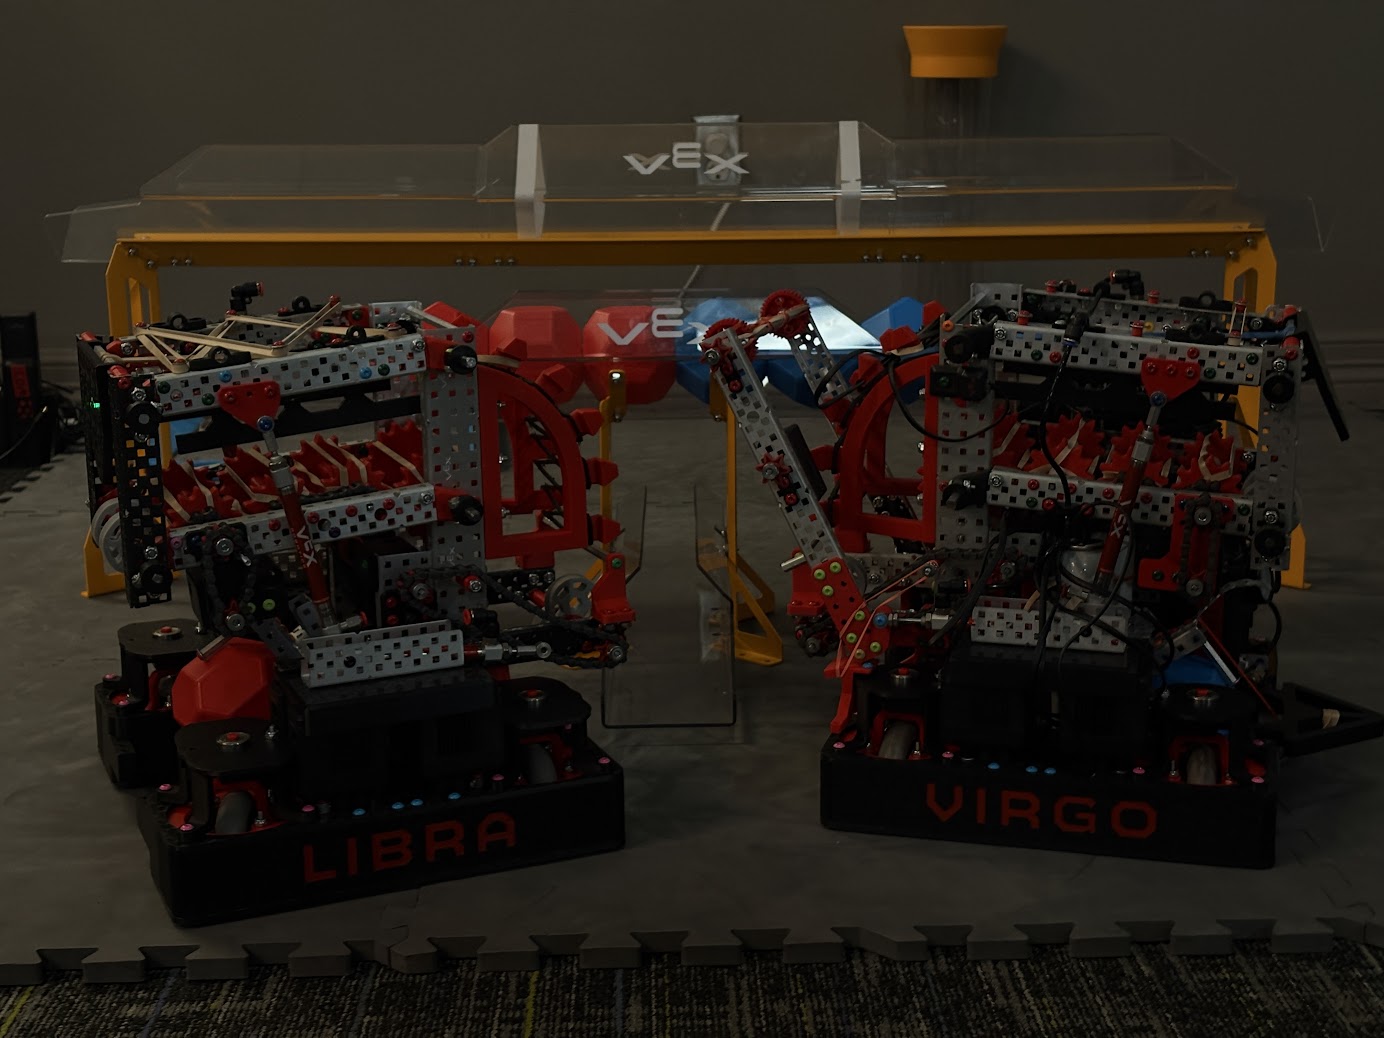
Push Back
Our most recent year of competition. This year, we ran skills at a local event. On the worldwide leaderboard we placed 134th with a score of 71 (35 in auto, 36 in drivers). We qualified for the World Championships in St. Louis, MO. Here, we placed 26th in our division with a win-loss ratio of 4-6. We showed up with a special robot showing off our Differential Swerve drivetrain!
Our Subteams
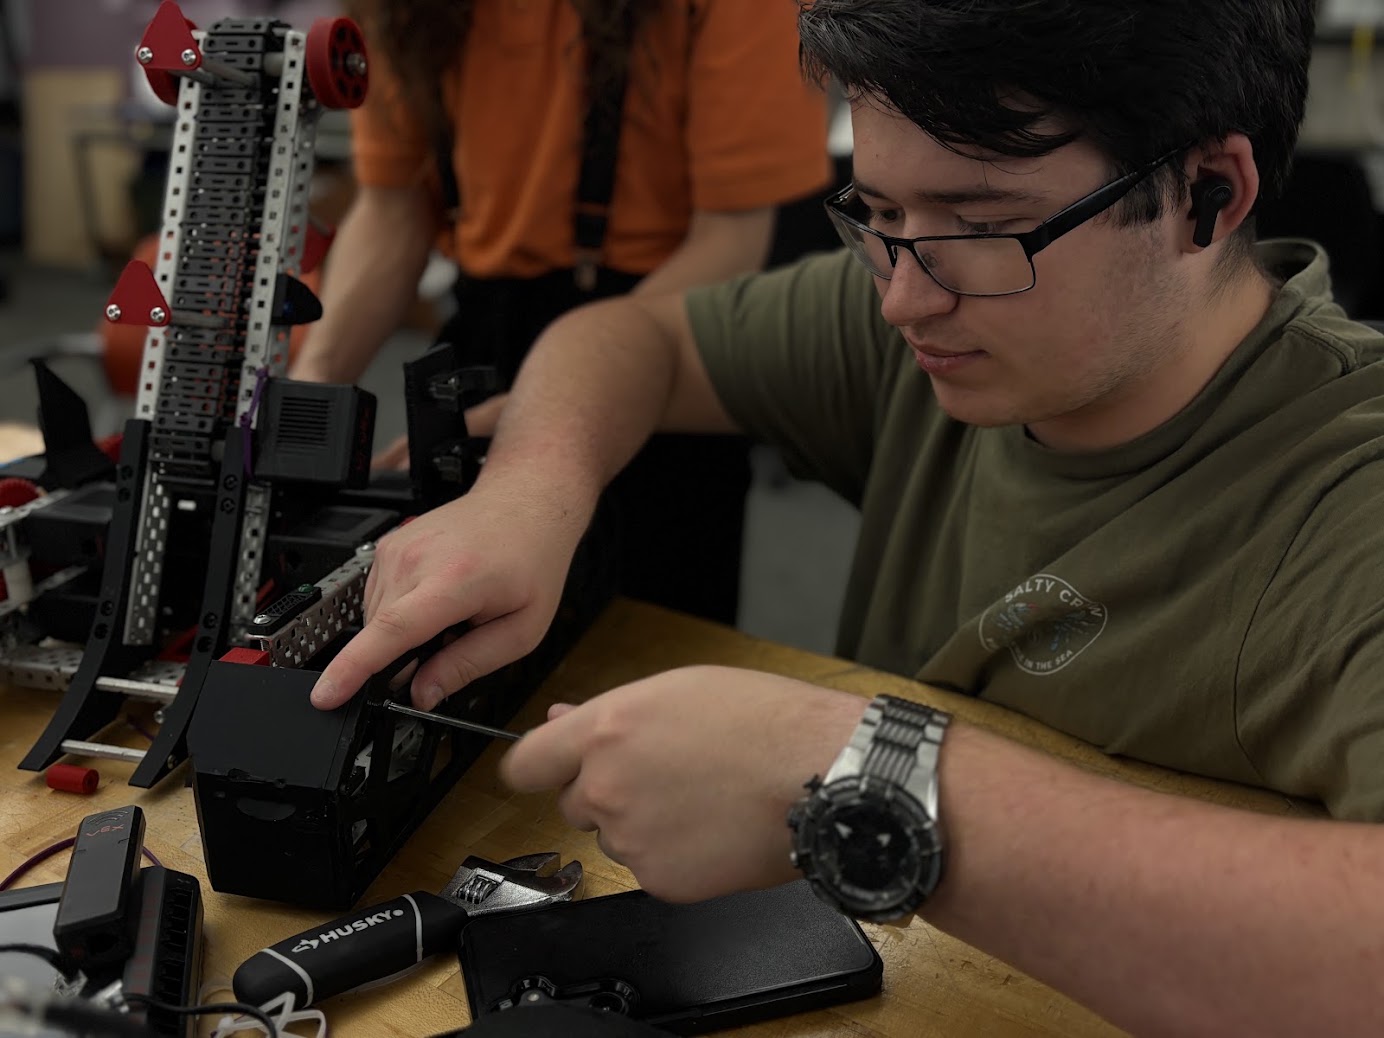
Mechanical
The Mechanical subteam designs and fabricates the physical robot.
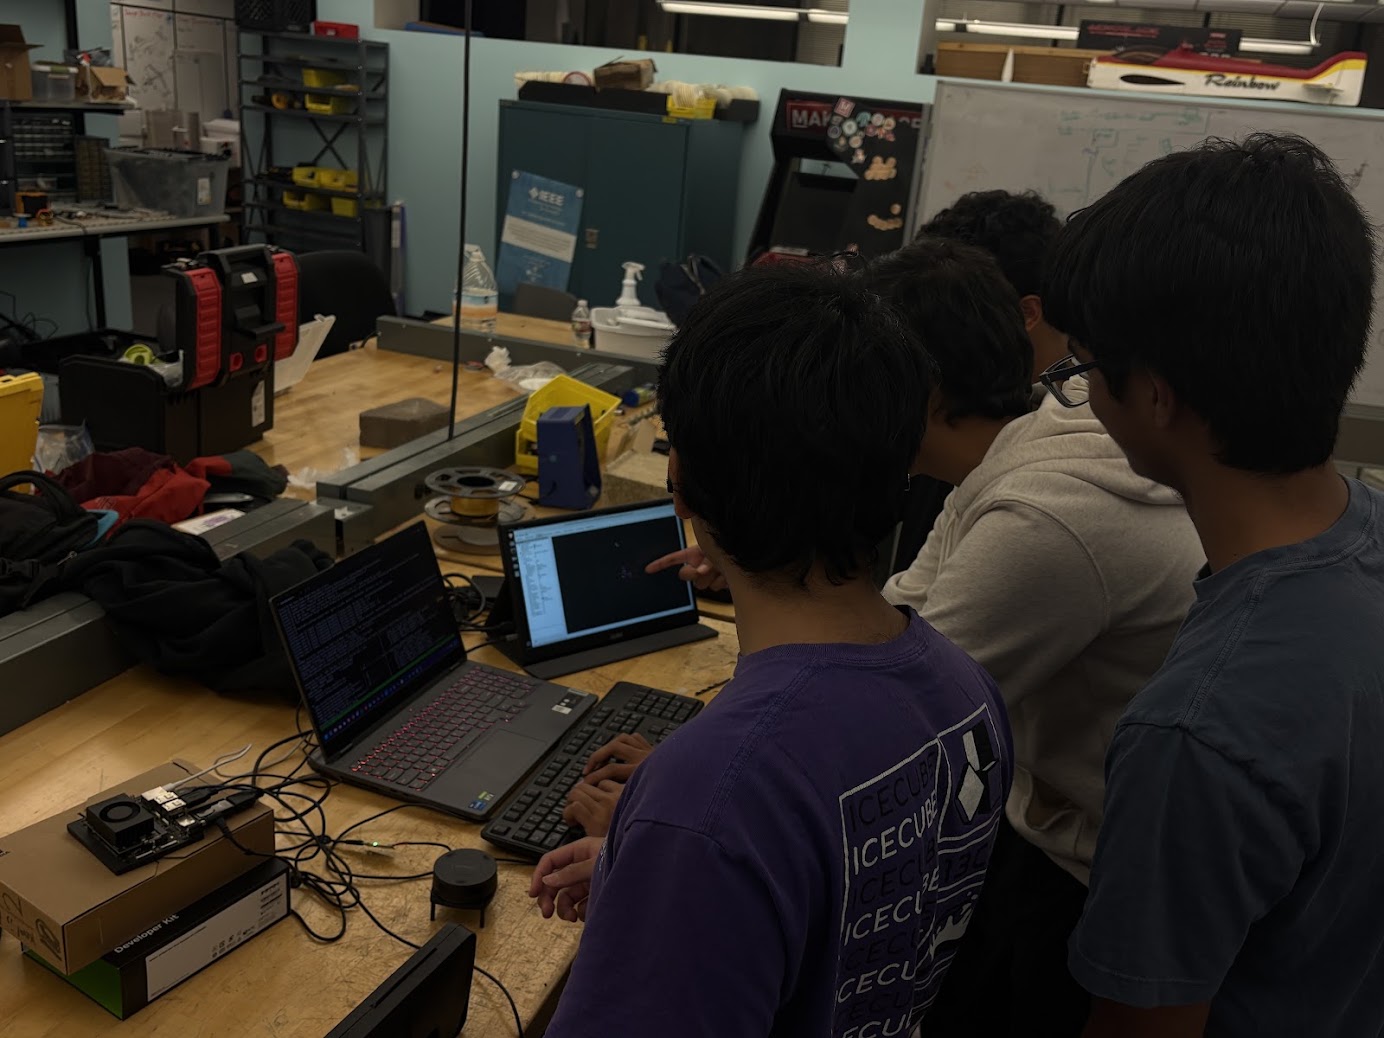
Software
The Software subteam programs the robot's autonomous routines and driver-control behaviors.
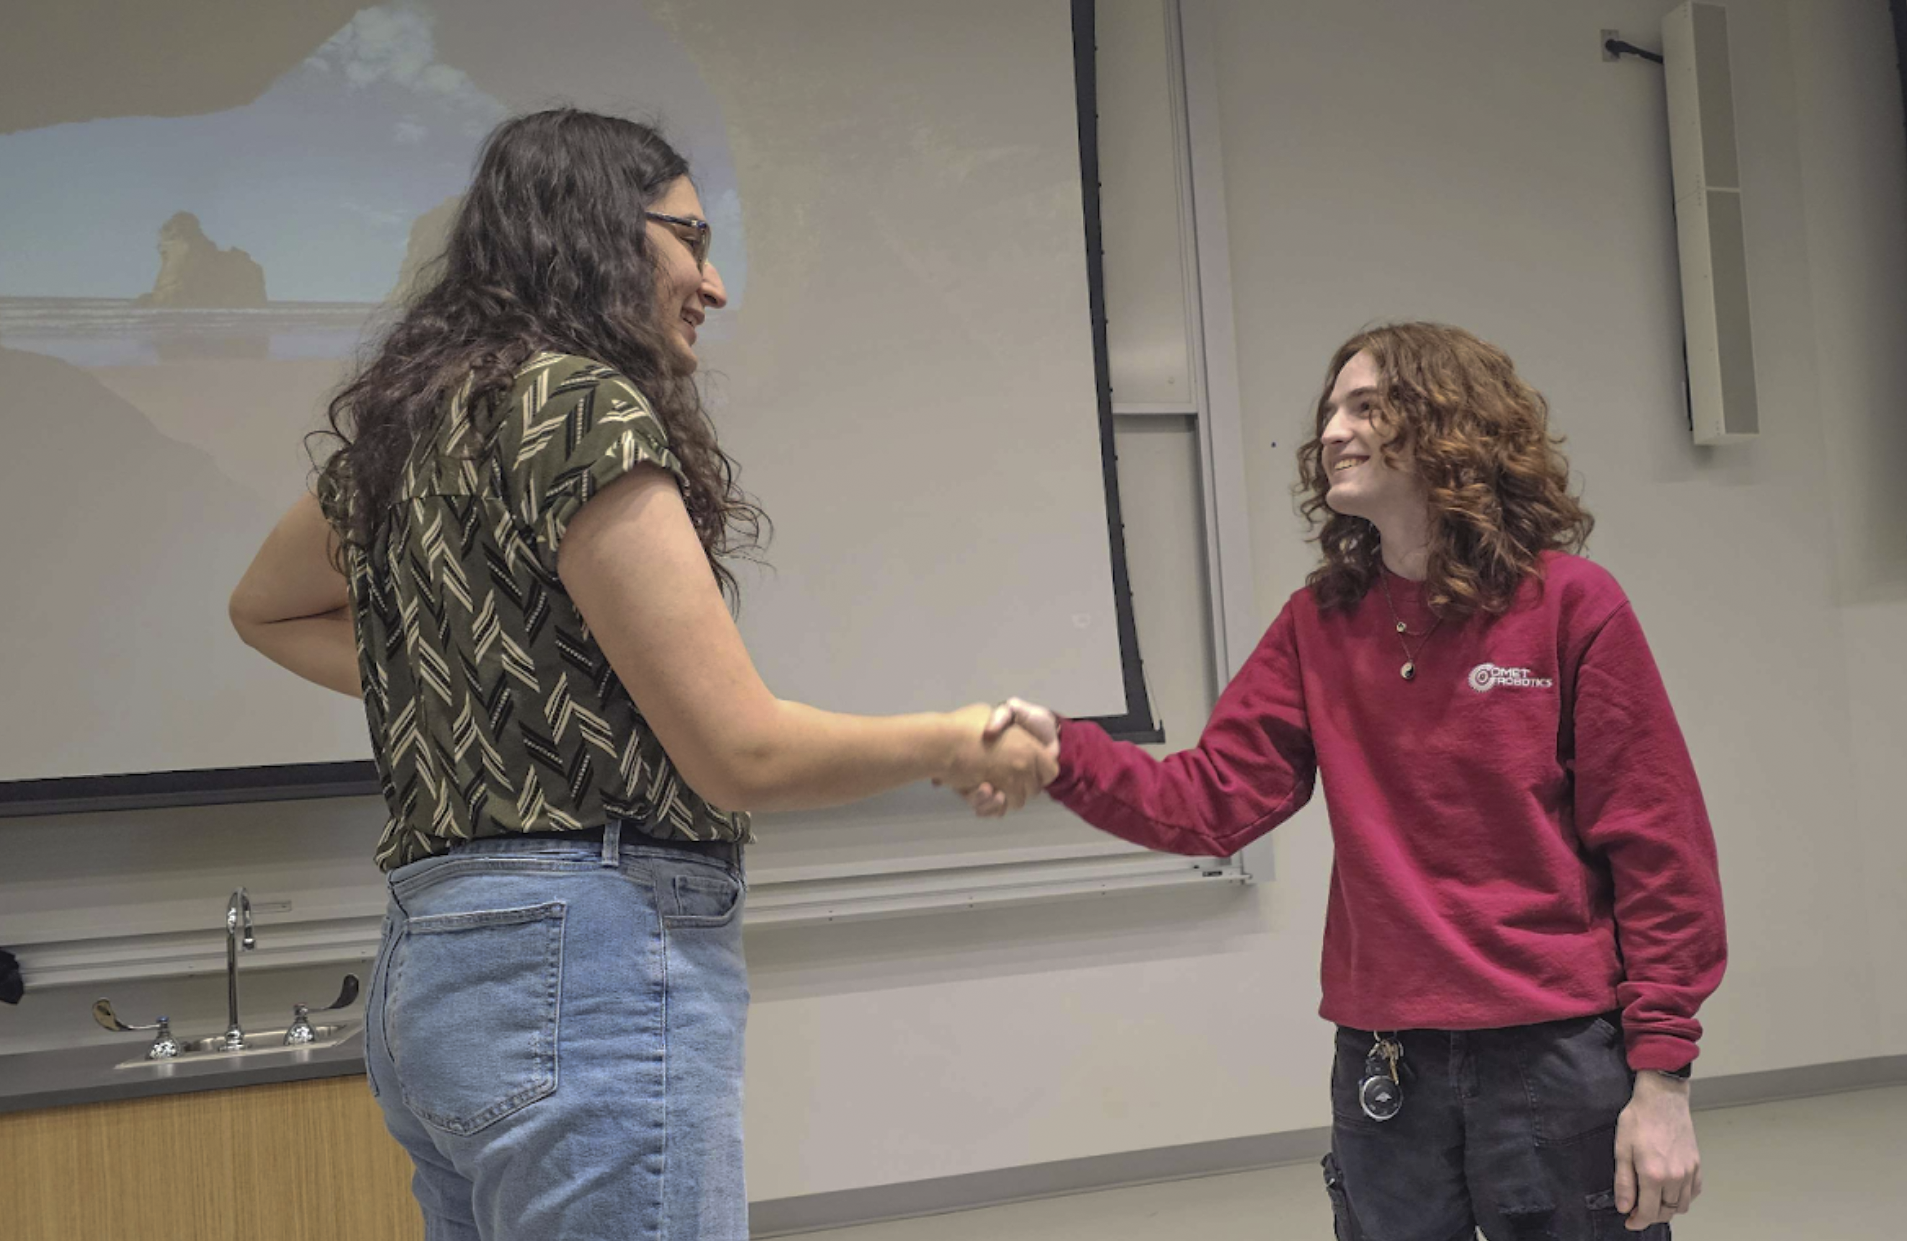
Business
The Business subteam handles sponsorship outreach and budget management.
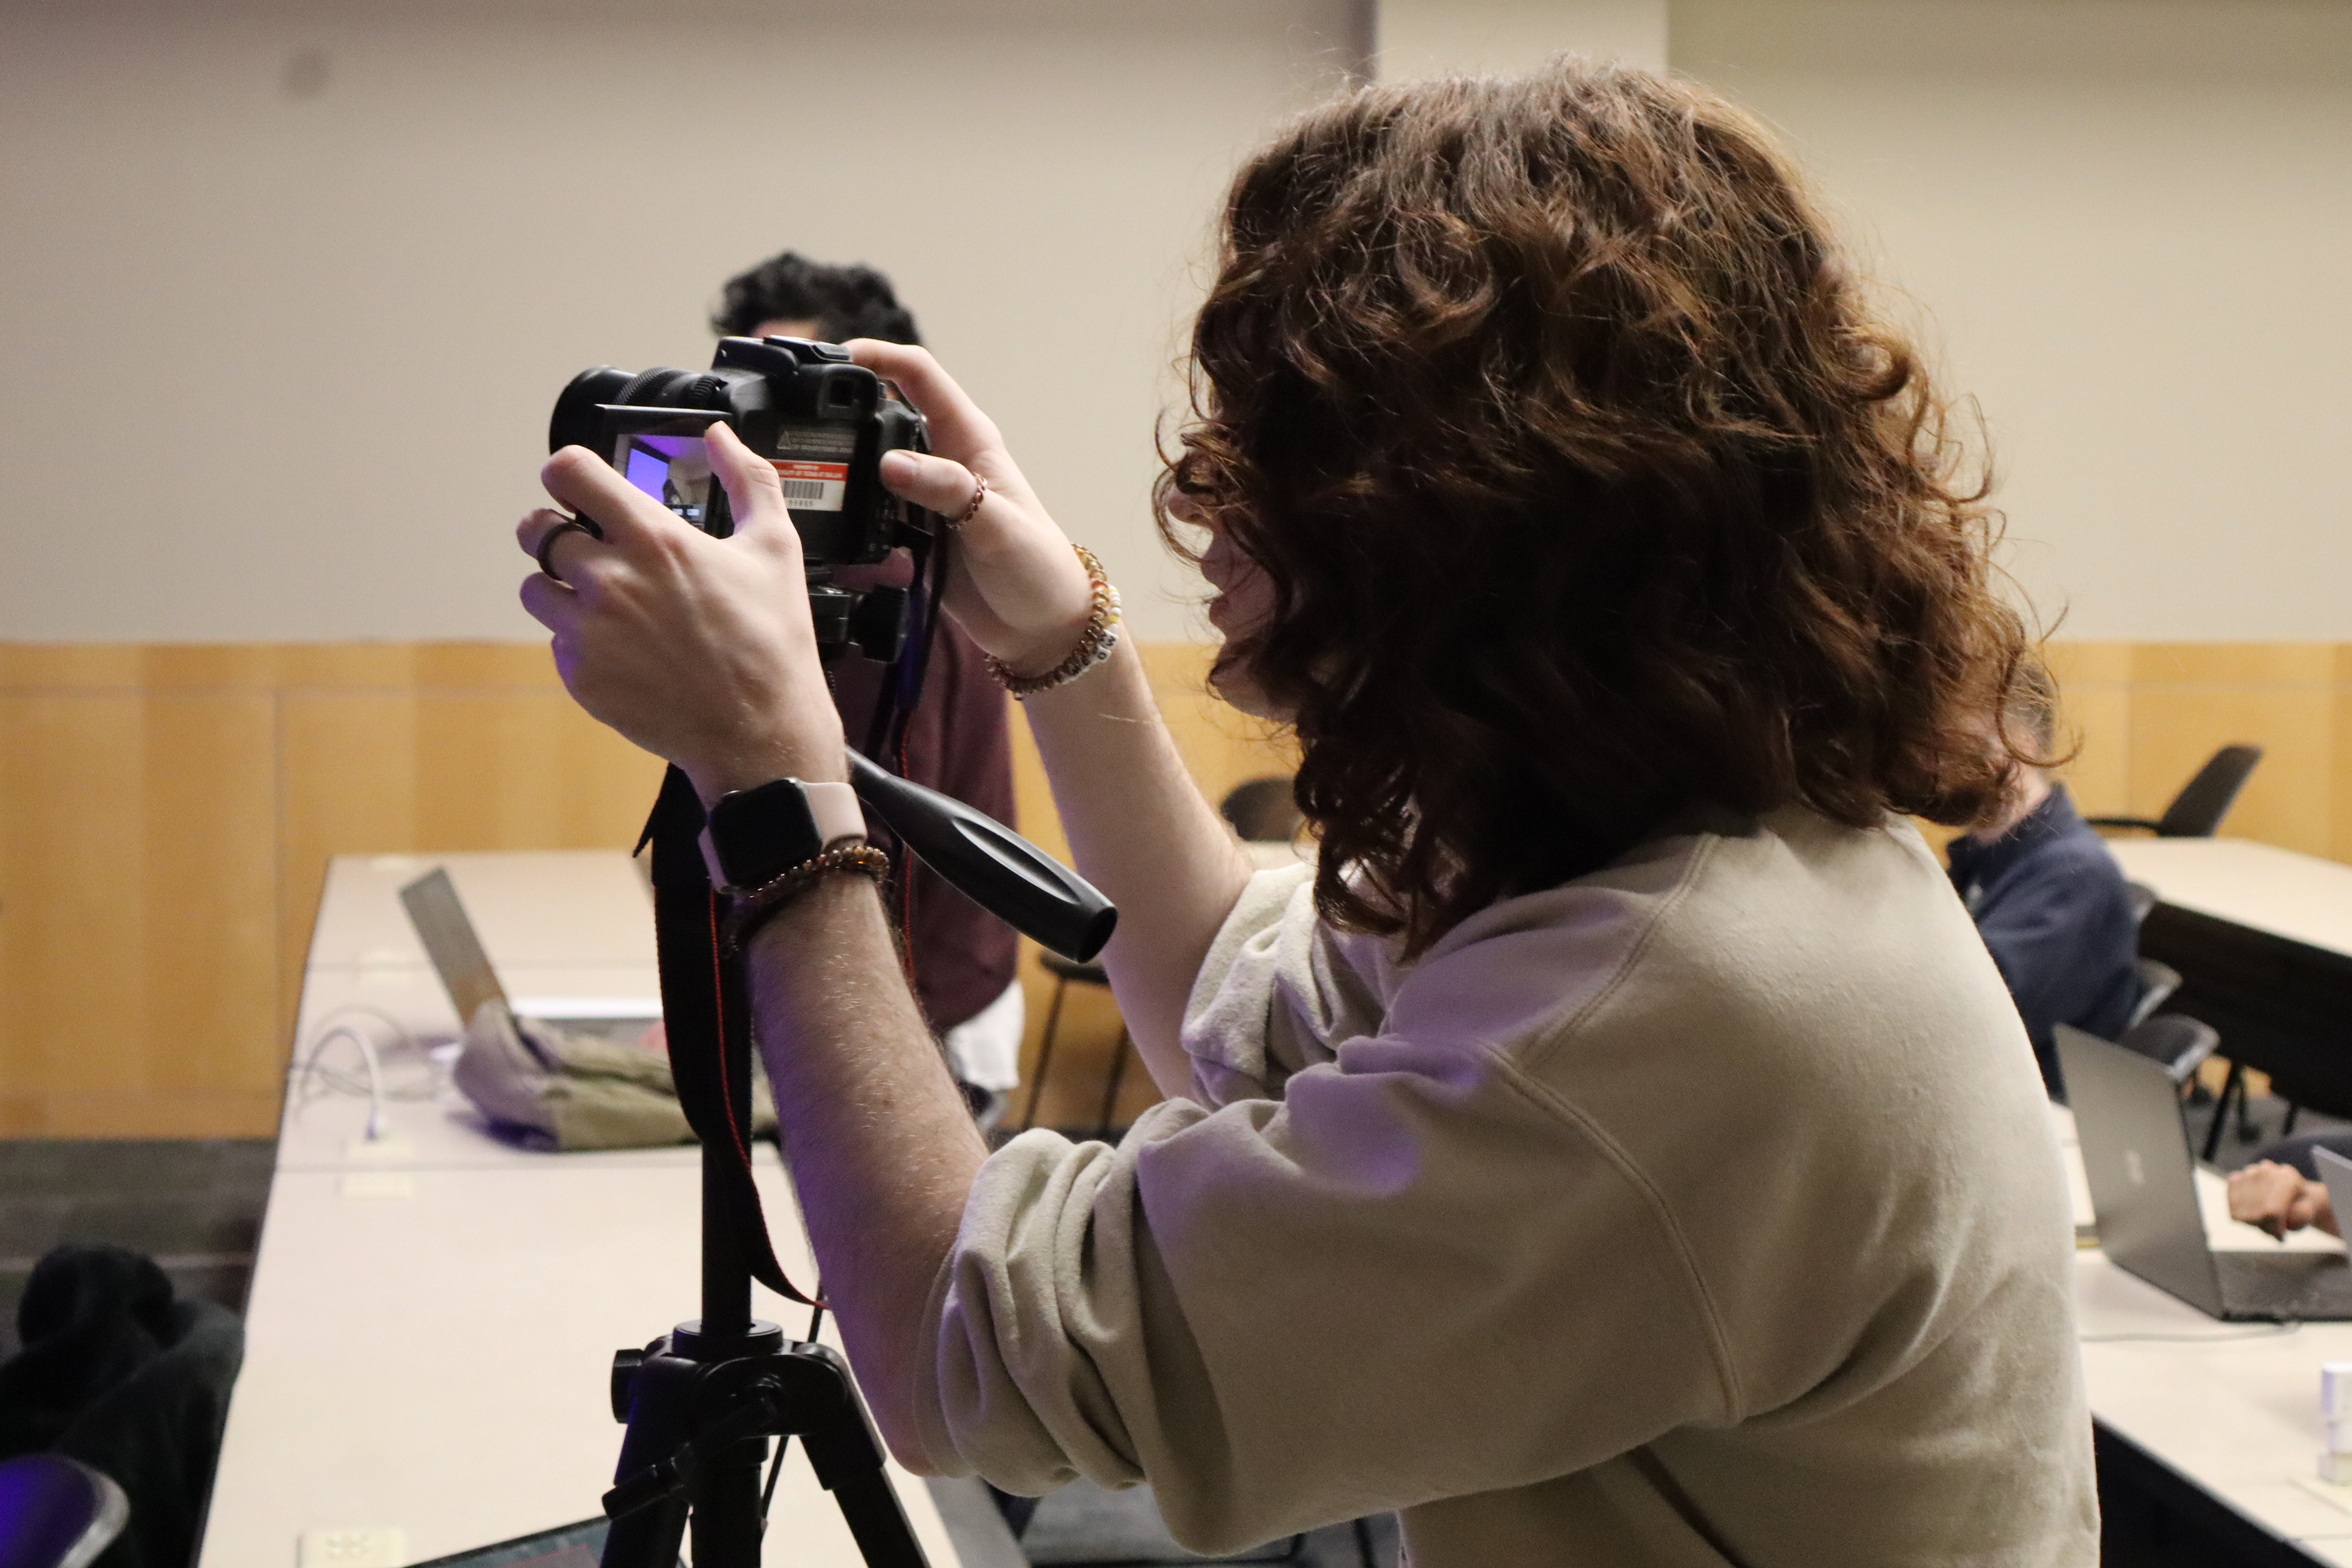
Marketing
The Marketing subteam manages social media, photography, and branding.
Join
Interested in getting involved in a project team? Come to a meeting and talk to a project manager or officer about how you can join. Our general meetings are on Mondays at 7pm* at the UTDesign Makerspace.